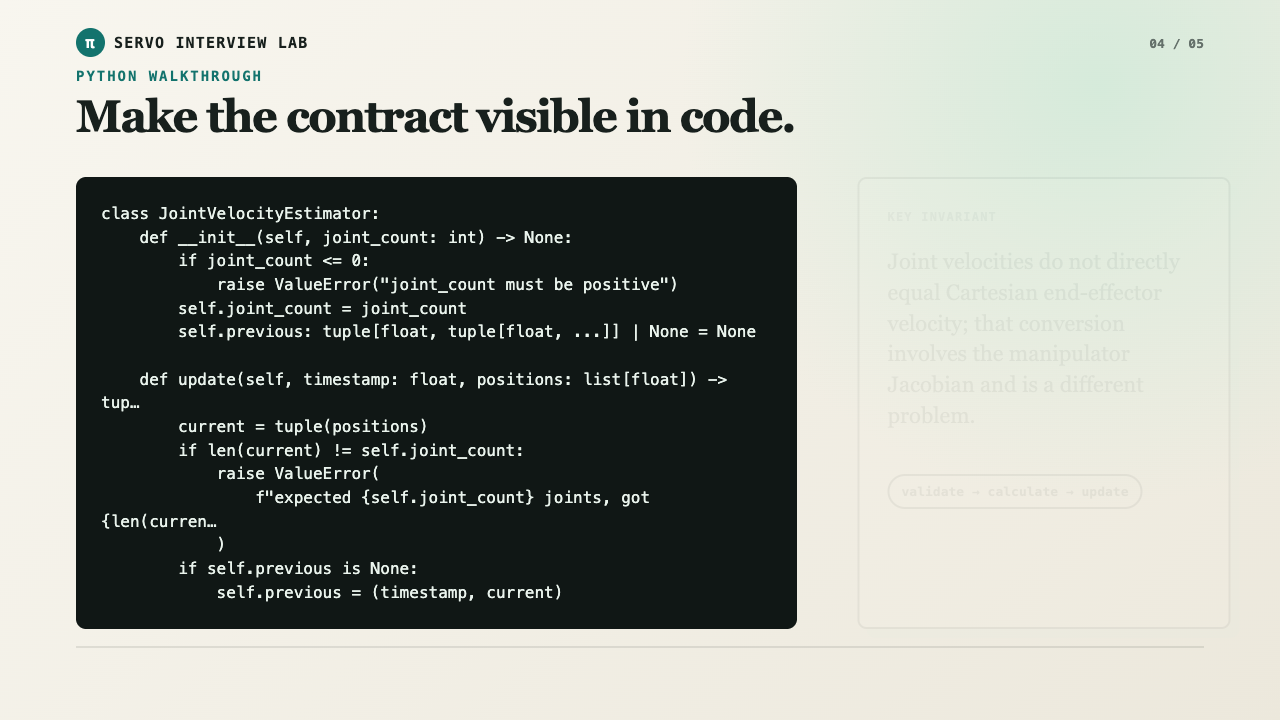
Q4. Extend the estimator to a robot arm, explained — HTML Docs
0:00 / 2:10
0.5×
0.75×
1×
1.25×
1.5×
2×